From rotor to rudder
Uncrewed aircraft and autonomous vessels act on their own sensors, with nobody on board to look out of the window. Gill builds the compact, low-power wind, weather and level measurement those platforms, and the sites they launch from, depend on.
Every gram, every watt.
Every reading counts.
On an autonomous platform the sensor is part of the control loop. Wind data sets launch and recovery limits and corrects navigation, fuel level sets range and return decisions, and weather data is often the mission itself. Every sensor also has to earn its place in a tight mass, power and integration budget.
Nobody on board to check. An uncrewed surface vessel (USV) weeks into a mission, or a UAV operating beyond visual line of sight, cannot stop for a sensor to be cleaned, reset or checked by hand. Gill ultrasonic wind sensors and capacitive level sensors have no cups, vanes or floats in their measurement mechanisms, removing mechanical components that can wear or stick when equipment is deployed remotely.
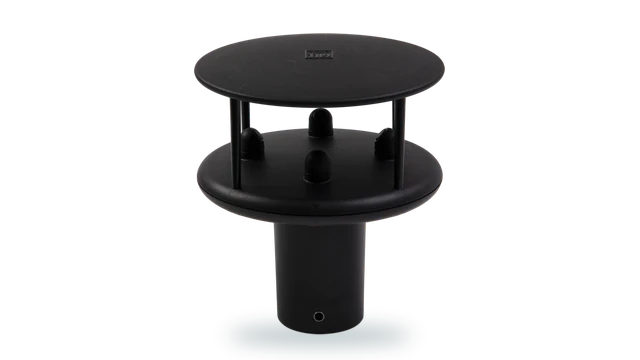
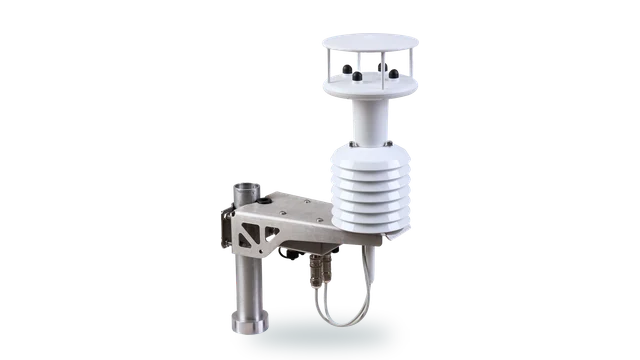
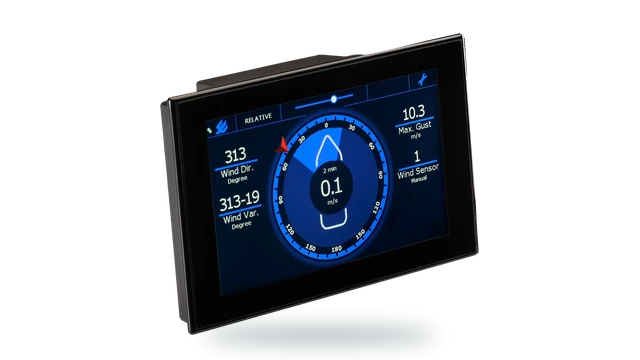
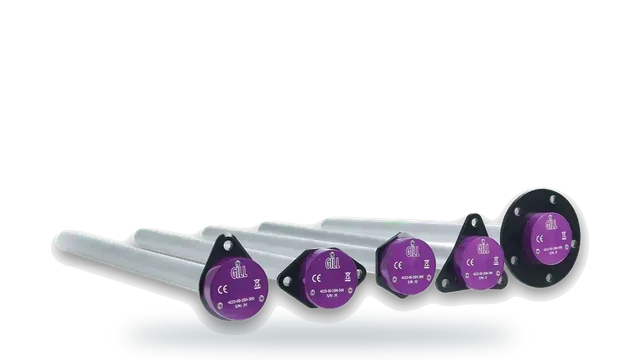
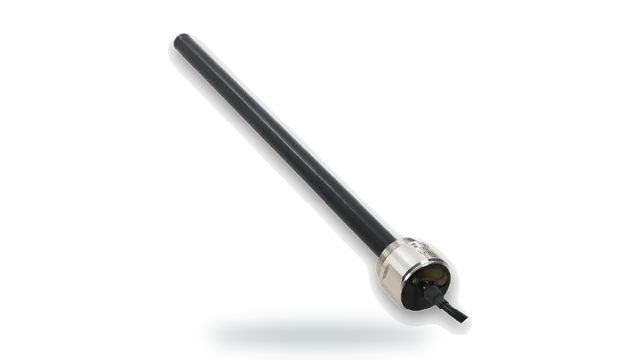
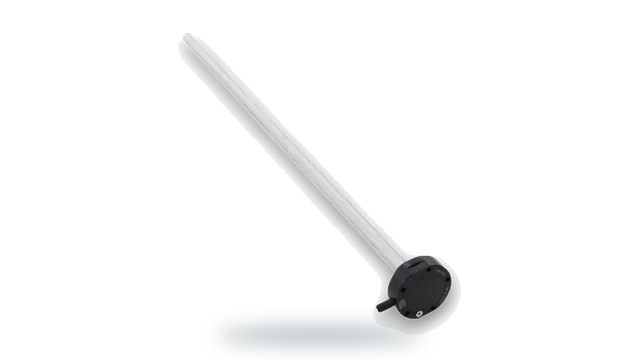
Every gram and milliwatt has to earn its place. On autonomous platforms, sensor weight and power consumption directly affect payload capacity and endurance. WindUltra weighs just 270 g with its 1 inch pole mount and draws under 100 mW when unheated in calm conditions. For weight-critical installations, LevelLite is a lightweight aluminium level sensor designed for platforms such as UAVs, where every gram matters.
Every sensor on an autonomous platform is a crew member
From the launch rail to the open sea, uncrewed aircraft and vessels act on their own measurements. Select a point to see where Gill sensors sit and what each one measures.
Wind on the airframe
A small UAV feels every gust. Wind measured on the airframe feeds flight control and lets the aircraft report the conditions it is flying through, without adding cups or vanes to the payload.
- WindUltra 2-axis ultrasonic, 270 g with its 1 inch pole mount, under 100 mW unheated in calm conditions, sealed to IP66, IP68 and IP69k, built for mobile platforms
UAV fuel and actuators
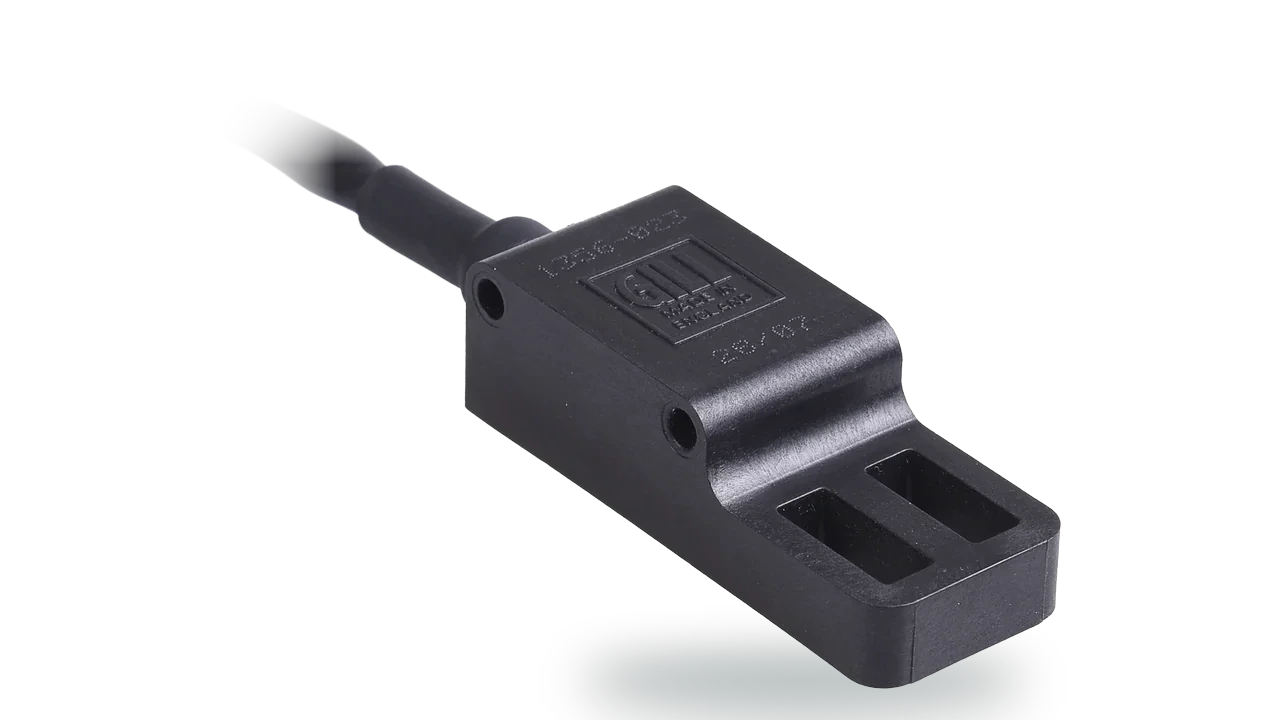
Fuel level sets range, endurance and the decision to return. A capacitive level sensor reads the tank continuously, with no float in the measurement and very little mass added to the airframe. The actuators that move the control surfaces need position feedback with no contact to wear.
- LevelLite lightweight aluminium capacitive level sensor, CAN and RS232 alongside voltage and current options, IP68
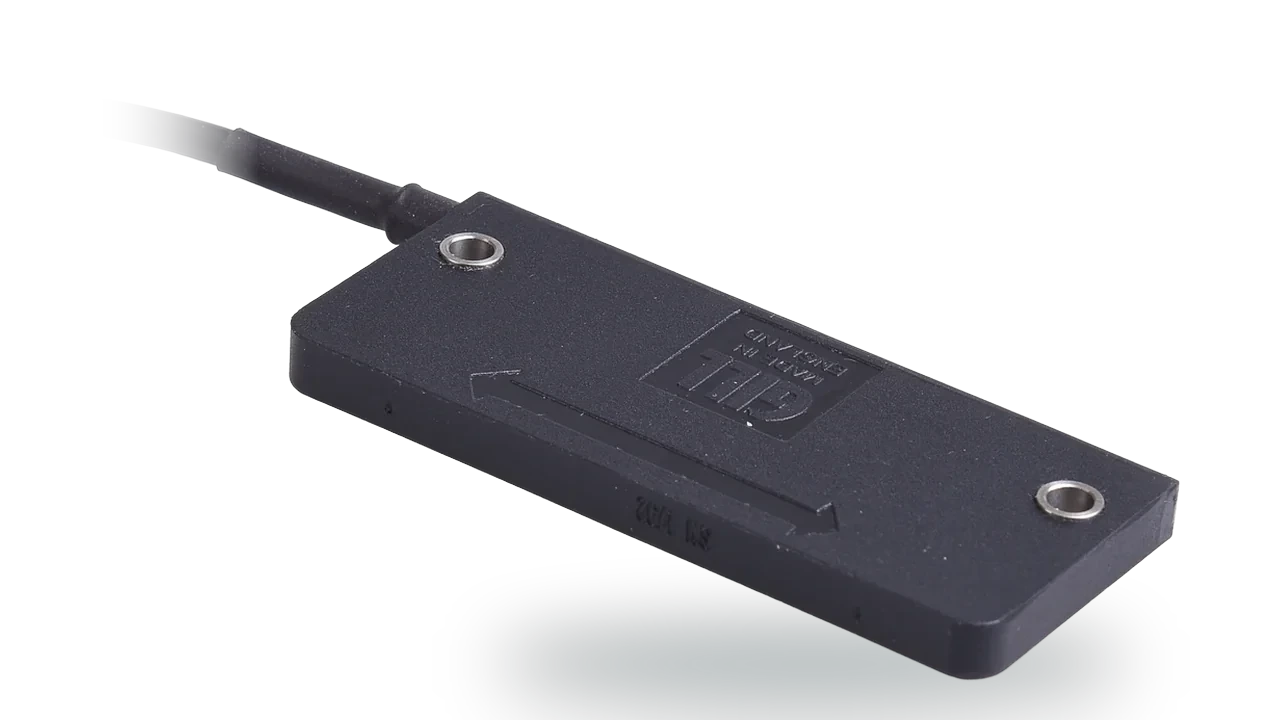
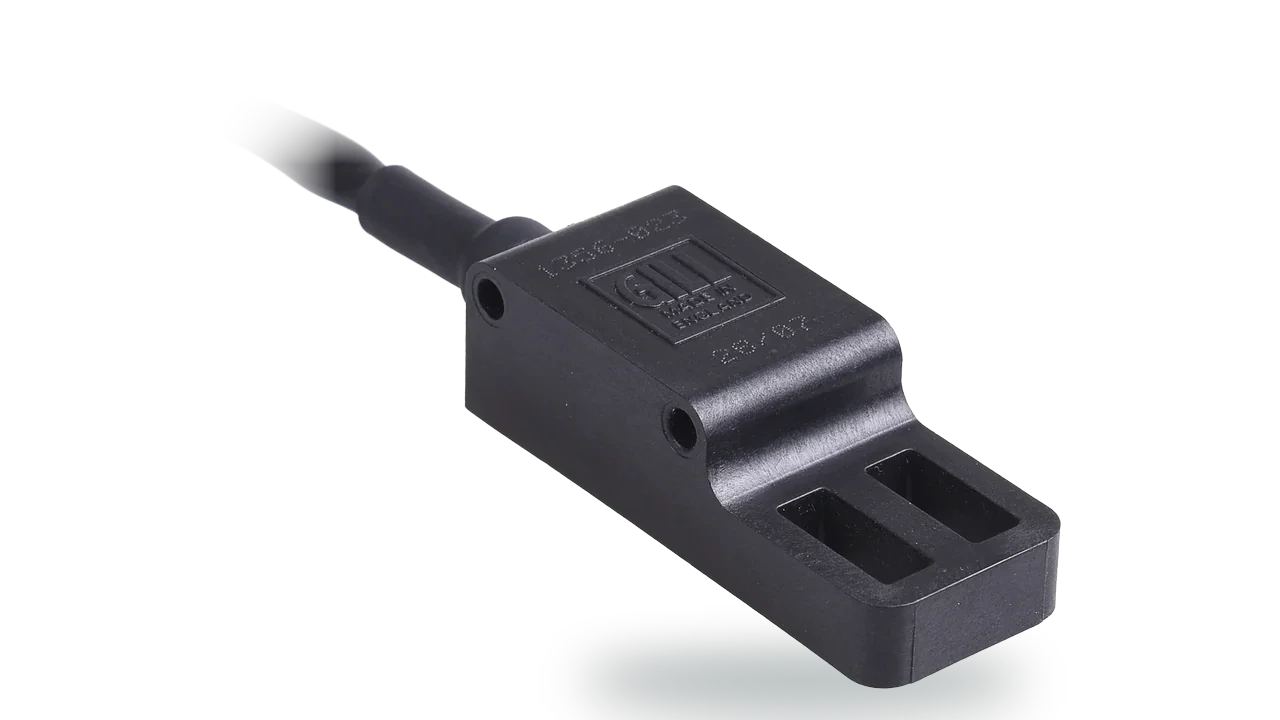
- Blade position sensors non-contact, with unlimited mechanical life, for airframe actuators
- Blade25 contactless linear position to 25 mm
- Blade Dual Output a second channel where redundancy is required
Launch and recovery wind
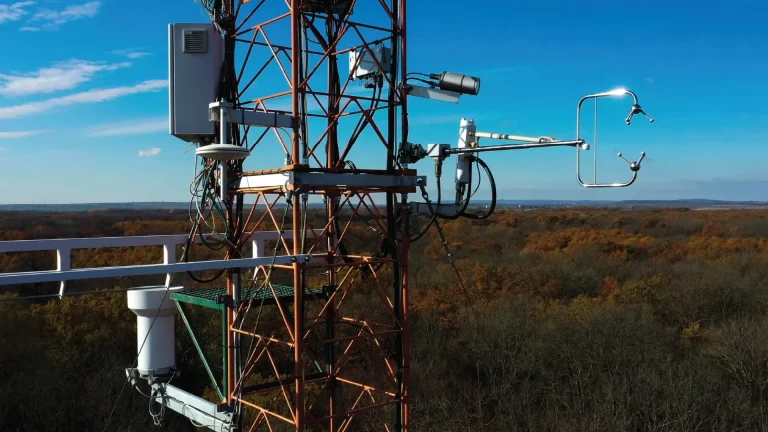
Wind at the launch rail or landing pad sets the go and no-go call for uncrewed aircraft, at fixed sites and deployable ones, and the reading has to be live when the operator makes it.
- WindSonic 60 0.5 kg ground reference for launch and recovery
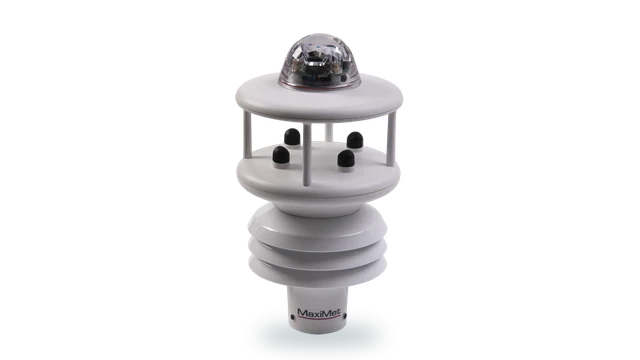
- MaxiMet GMX200 portable wind reference for a temporary operating site, one cable and one output string
- MaxiMet GMX500 wind, temperature, humidity and pressure in one unit at the ground control station
- MaxiMet GMX603 adds high-accuracy optical rainfall for the go or no-go decision
- MetConnect where sensors need to sit at separate heights
USV wind and weather
An uncrewed surface vessel uses wind and weather data for navigation, station keeping and mission reporting, with nobody on deck to wipe or check the instrument.
- WindUltra 270 g, sealed to IP66, IP68 and IP69k, heated as standard, for small USVs
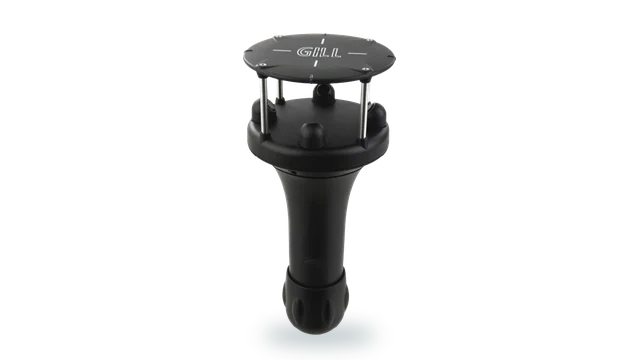
- WindSonic low-cost 2-axis ultrasonic wind measurement in a lightweight polycarbonate body
- MaxiMet GMX260 marine wind model with a 6-axis compass for moving platforms, IP66
- MaxiMet Marine GMX560 wind, temperature, humidity and pressure with a 6-axis compass, IP66 and IP68
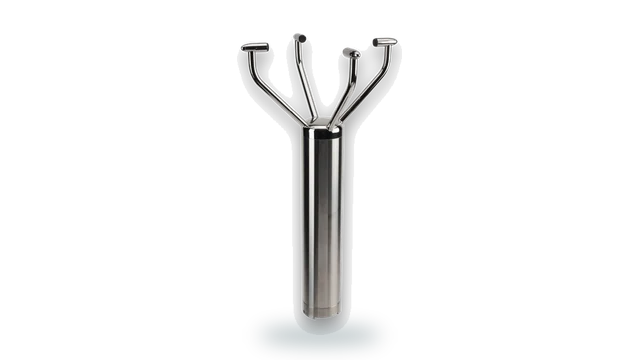
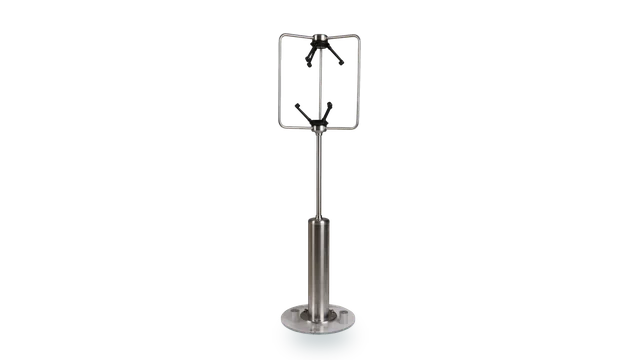
- WindObserver stainless steel ultrasonic wind for larger autonomous vessels
- MetConnect a modular station where the platform needs more flexibility in how its sensors are arranged
Fuel and fluid reserves
Remote operators need to know what is left in the fuel, water and oil tanks without opening a hatch. Continuous level readings travel back over the vessel data link.
- LevelLite lightweight aluminium fuel level for uncrewed vessels, IP68
- LevelPro stainless steel capacitive level, no moving parts
- LevelSlick non-stick coated probe for bilge water and other dirty or viscous liquids
Rudder and actuator position
Rudders, thrusters and actuators all have positions that matter to control. Non-contact position sensing gives feedback with no physical contact at the measurement point.
- Blade25 or Blade60 contactless linear position to 25 mm or 60 mm, IP67
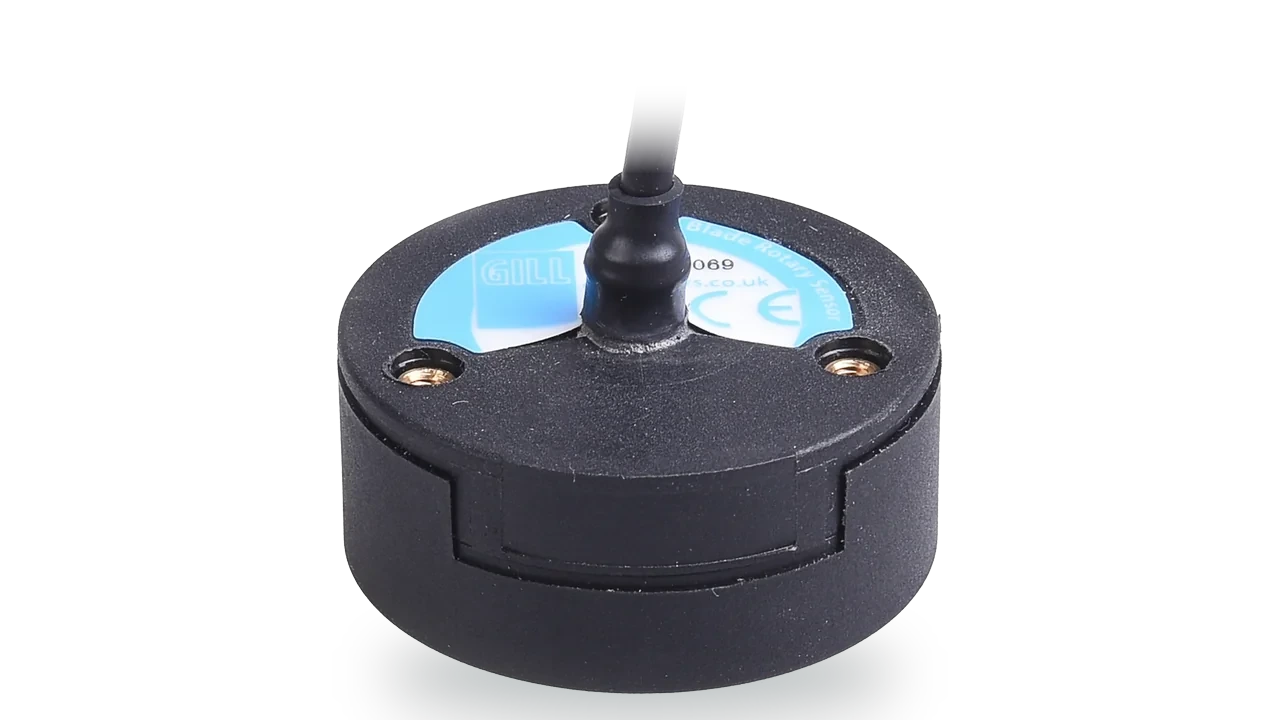
- Blade360 rotary position through the full 360 degrees
Machinery condition
For engines, gearboxes and thruster drives, oil condition monitoring can detect ferrous wear debris and help identify a developing issue before it disrupts a mission.
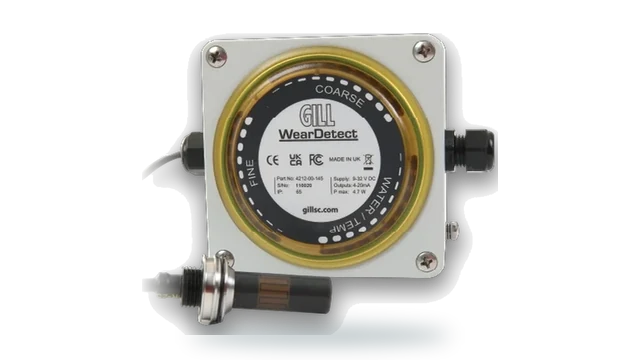
- WearDetect fine and coarse debris, water and oil temperature in one sensor
Autonomous ships
MaxiMet provided the weather measurement on the Mayflower Autonomous Ship, written up as a Gill application note, and the UK Met Office has trialled the AutoNaut uncrewed vessel as a replacement for weather buoys.
- MaxiMet compact weather station, as used on the Mayflower
- MaxiMet Marine GMX560 wind, temperature, humidity and pressure with a 6-axis compass, IP66 and IP68
- WindObserver stainless steel ultrasonic wind for the main mast
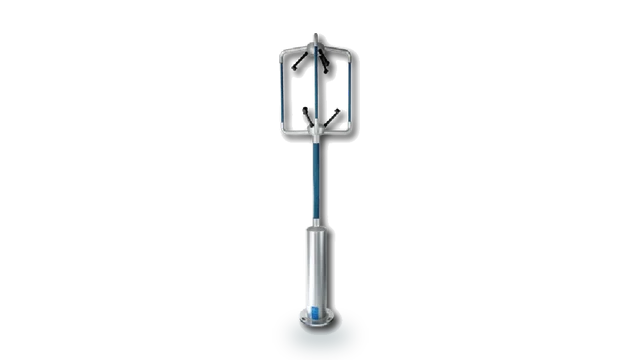
- WindMaster 3-axis ultrasonic for research-grade wind and turbulence, as used on Saildrone USVs
Find your autonomous application
UAV and launch sites
Wind at the launch and recovery point sets the go and no-go limits for uncrewed aircraft, at fixed sites and deployable ones.
Explore UAV and launch sitesUSV and autonomous marine
Wind, weather and level measurement for uncrewed surface vessels that have to keep working when nobody is on board.
Explore USV and autonomous marineFuel level sensing for UAVs
How combustion-powered UAVs balance fuel, payload and endurance, and where a capacitive level sensor fits in the airframe.
Read the guideAlready crossing oceans without a crew
MaxiMet provided the weather measurement on the Mayflower Autonomous Ship, and the UK Met Office has trialled the AutoNaut uncrewed vessel as a replacement for weather buoys. Both are written up as Gill application notes.
WindUltra for compact wind measurement on UAVs and small USVs, MaxiMet for an integrated weather station on larger vessels, and LevelLite for fuel and fluid level where weight matters.
Frequently asked questions
WindUltra is the Gill wind sensor built for compact, mobile platforms such as UAVs and small uncrewed surface vessels. WindUltra is a 2-axis ultrasonic anemometer with no moving parts, weighing 270 g with its 1 inch pole mount and drawing under 100 mW unheated in calm conditions. It is sealed to IP69k, also rated IP66 and IP68, measures up to 75 m/s and has heating fitted as standard.
Fuel level on a combustion-powered UAV is usually measured with a sensor that adds as little mass as possible to the airframe. LevelLite is the lightweight Gill capacitive level sensor in aluminium, with no moving parts in the measurement, CAN and RS232 outputs alongside voltage and current options, IP68 sealing and a +5 to +32 V supply. The UAV fuel level guide explains the trade-offs.
A Gill MaxiMet compact weather station has already run on an autonomous vessel: MaxiMet provided the weather measurement on the Mayflower Autonomous Ship, written up in AN0062. The configuration for a vessel depends on the measurements, outputs and mounting needed, so the model is confirmed with a Gill engineer against the platform before it is specified.
Wind at the launch and recovery point decides whether an uncrewed aircraft can safely take off and land, so operators set go and no-go limits against a live wind reading. An ultrasonic wind sensor gives that reading with no cups or vanes to stall, wear or ice. UAV and launch sites covers the sensors used at fixed and deployable sites.
An ultrasonic wind sensor on a moving UAV or vessel measures the apparent wind, which is the air movement relative to the platform. True wind is then calculated by combining that reading with the platform speed and heading, usually from GPS and a compass. True wind versus apparent wind and wind on moving platforms explain how this is done.
Measuring for an autonomous platform?
Tell us about the platform, its mass and power budget and the data bus. We will tell you plainly what we would measure, where, and with which output.
We aim to respond in one working day.